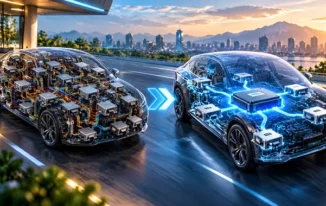

Electric vehicles (EVs) rely on advanced battery systems to deliver reliable performance, extended driving range, and safe operation. At the center of these systems is the Battery Management System (BMS), which monitors battery conditions, estimates available energy, manages charging and discharging, and helps prevent dangerous operating conditions. As battery technology evolves, microcontroller-based battery management system architectures for electric vehicle thermal optimization are becoming increasingly important for improving battery efficiency, durability, and safety.
A well-designed BMS combines hardware components, embedded software, sensing technologies, and control algorithms to maintain battery cells within their recommended operating limits. By integrating state-of-charge (SoC) estimation, thermal regulation, and cell-balancing algorithms, engineers can develop intelligent battery management architectures that respond to changing driving conditions and temperature variations.
Understanding Microcontroller-Based Battery Management Systems
A microcontroller-based BMS uses one or more embedded microcontrollers to collect battery measurements, process sensor data, execute control algorithms, and communicate with other vehicle systems. Unlike a passive monitoring circuit, a microcontroller-based architecture can perform continuous calculations and make control decisions based on real-time battery conditions.
Typical BMS hardware includes voltage-monitoring circuits, current sensors, temperature sensors, cell-monitoring integrated circuits, communication interfaces, and protection circuitry. The microcontroller coordinates these components through interfaces such as analog-to-digital converters (ADCs), Serial Peripheral Interface (SPI), Inter-Integrated Circuit (I²C), Controller Area Network (CAN), and Universal Asynchronous Receiver-Transmitter (UART), depending on the system design.
For larger battery packs, the architecture may distribute monitoring responsibilities across several electronic control units. Cell-monitoring units measure individual cell voltages and temperatures, while a central controller processes the collected information and coordinates battery-level decisions.
This distributed approach reduces wiring complexity, supports modular battery designs, and allows the system to scale for different vehicle platforms.
Key Architectural Components of an EV Battery Management System
1. Battery Monitoring and Sensor Interfaces
Accurate monitoring is the foundation of effective battery management. Voltage measurements help identify abnormal cell conditions, current measurements support energy estimation, and temperature sensors reveal thermal variations throughout the battery pack.
The hardware-software interface must ensure that these measurements are accurate, time-aligned, and resistant to electrical noise. Engineers may use dedicated battery-monitoring integrated circuits to measure multiple cells and transmit the results to the microcontroller.
Sensor placement is equally important. Temperature sensors should be positioned to capture meaningful thermal variations, especially in areas where heat accumulation is more likely. In larger battery packs, monitoring several locations helps identify localized hot spots that a single sensor might miss.
Signal filtering, sensor diagnostics, calibration, and plausibility checks help the software distinguish genuine battery changes from measurement errors.
2. Microcontroller and Embedded Software
The microcontroller serves as the computational center of the BMS. It executes algorithms for SoC estimation, thermal monitoring, cell balancing, fault detection, and communication.
The software architecture commonly separates functions into modules. A sensing module acquires data, an estimation module calculates battery states, a thermal-control module determines cooling requirements, and a diagnostic module evaluates potential faults.
Real-time scheduling ensures that critical measurements and protection-related tasks receive sufficient processing time. Software must also handle communication failures, invalid sensor readings, watchdog events, and unexpected operating conditions.
For safety-critical applications, the architecture should include defined fault responses and verification procedures. Independent hardware protection may also be necessary so that critical electrical limits can be enforced even if the main software fails.
State-of-Charge Estimation and Energy Management
State of charge indicates how much usable charge remains in a battery relative to its estimated available capacity. Reliable SoC estimation helps drivers understand remaining range and allows vehicle controllers to manage power delivery.
A common method is coulomb counting, which integrates measured current over time. Although computationally efficient, it can accumulate errors caused by sensor offsets, uncertain initial conditions, and changes in battery capacity.
Open-circuit voltage estimation can provide a useful reference under suitable rest conditions, but its accuracy depends on the battery chemistry, temperature, and the relationship between voltage and SoC.
More advanced systems combine current measurements, voltage observations, temperature data, and battery models. Kalman-filter-based approaches, including the extended Kalman filter, can estimate SoC by comparing predicted battery behavior with measured values.
The microcontroller must execute these calculations within the available processing and timing budgets. Estimation frequency, model complexity, memory requirements, and sensor quality should therefore be considered together when selecting the hardware platform.
Accurate SoC estimation also supports thermal optimization. For example, the battery controller can use estimated SoC and predicted power demand to coordinate charging limits, regenerative braking, and thermal-management requests. However, SoC alone does not indicate whether a battery is thermally safe; temperature, current, voltage, and other relevant constraints must also be evaluated.
Thermal Regulation and Temperature-Aware Control
Battery temperature directly affects charging performance, power capability, aging, and safety. High temperatures can accelerate degradation, while low temperatures can restrict charging and increase internal resistance. Uneven temperature distribution may also cause cells within the same pack to age at different rates.
A microcontroller-based BMS monitors temperature sensors and evaluates whether the battery is operating within its permitted temperature range. Depending on the vehicle design, the controller may request cooling, heating, reduced charging current, or limited power output.
Thermal-management systems may use air cooling, liquid cooling, refrigerant-based cooling, or other approaches suited to the battery pack. The BMS generally coordinates with a dedicated thermal controller rather than directly controlling every actuator.
A temperature-aware control strategy can incorporate several inputs:
- Individual cell or module temperatures.
- Battery current and voltage.
- Estimated SoC and state of health.
- Charging or driving power demand.
- Ambient temperature and available cooling capacity.
- Predicted temperature changes under expected operating conditions.
Simple threshold-based control is relatively easy to implement, but it can produce frequent switching near temperature limits. Hysteresis, filtering, and appropriately tuned control loops help reduce unnecessary cycling of pumps, fans, valves, and other thermal components.
More advanced systems use thermal models to predict temperature changes and initiate cooling before a critical threshold is reached. Model predictive control may improve thermal performance by considering future power demand and actuator constraints, although it requires additional computation and careful model validation.
The goal is not simply to minimize temperature. Effective thermal optimization balances battery safety, energy consumption, performance, temperature uniformity, and long-term degradation.
Cell-Balancing Algorithms for Improved Battery Performance
Battery cells gradually develop differences in charge, capacity, internal resistance, and temperature. These variations can limit usable pack capacity because the weakest or most constrained cell may determine when charging or discharging must stop.
Cell balancing reduces certain differences between cells and helps the pack operate more consistently.
Passive Cell Balancing
Passive balancing dissipates excess energy from higher-voltage cells through resistors. It is comparatively simple, inexpensive, and straightforward to implement.
The microcontroller identifies cells that require balancing and activates the relevant balancing switches according to voltage thresholds, timing rules, and thermal constraints.
However, the energy converted into heat must be managed carefully. Excessive balancing activity can increase localized temperatures and create additional thermal-management demands.
Active Cell Balancing
Active balancing transfers energy between cells or between cells and other energy-storage elements instead of dissipating all excess energy as heat. Depending on the design, this can improve energy utilization and reduce balancing losses.
Active-balancing circuits may use inductors, capacitors, transformers, or converter-based topologies. Their control algorithms are generally more complex because the controller must coordinate switching, energy transfer, voltage measurements, and electrical protection.
The best balancing strategy depends on battery chemistry, pack size, cost targets, expected operating conditions, and thermal constraints.
Integrating Cell Balancing with Thermal Optimization
Cell balancing and thermal management should not operate as completely independent functions. Passive balancing can generate localized heat, while differences in cell temperature can influence voltage behavior and charging limits.
A coordinated BMS can therefore consider cell voltage, temperature, balancing current, and available cooling capacity when determining which cells to balance and when.
For example, if a cell is approaching its temperature limit, the controller may postpone nonessential balancing activity until thermal conditions improve. Any such decision must preserve required cell protection and remain within the battery manufacturer’s operating limits.
Designing the Hardware-Software Interface
The quality of the hardware-software interface determines how effectively the BMS can observe and control the battery pack. A robust architecture must connect physical measurements with software decisions while accounting for timing, communication reliability, electrical isolation, and fault handling.
Several design considerations are particularly important.
Measurement integrity: Analog front ends, ADC resolution, calibration, filtering, and sensor placement affect the accuracy of voltage, current, and temperature measurements.
Communication reliability: SPI or other local interfaces may connect the microcontroller to battery-monitoring devices, while isolated communication links may connect separate battery modules. CAN is commonly used for communication between vehicle controllers and the BMS.
Electrical isolation: High-voltage battery packs require suitable isolation between high-voltage circuitry and low-voltage control electronics wherever the system architecture and safety requirements demand it.
Real-time execution: Measurement acquisition, protection checks, state estimation, and thermal-control decisions must meet their timing requirements even when communication errors or high computational loads occur.
Fault diagnostics: The software should identify sensor failures, implausible readings, communication timeouts, overtemperature conditions, and other abnormal states. Responses may include limiting current, requesting cooling, opening contactors, or entering a defined safe state, depending on the fault and system design.
Cybersecurity and updates: Secure communication, controlled software updates, authentication, and protection against unauthorized access help maintain the integrity of increasingly connected vehicle systems.
Together, these elements allow the BMS to transform raw measurements into reliable battery-control decisions.
Distributed, Centralized, and Modular BMS Architectures
Different electric vehicles require different approaches to battery management. Three common architectural patterns are centralized, distributed, and modular designs.
A centralized BMS places much of the monitoring and processing functionality in a single controller. It can simplify coordination and reduce duplicated processing, but large numbers of sensor connections may increase wiring complexity.
A distributed architecture places cell-monitoring electronics near battery modules and uses communication links to share measurements with a supervisory controller. This approach can reduce long sensor-wire runs and support larger battery packs, although it introduces additional communication and synchronization requirements.
A modular architecture organizes monitoring and control functions into reusable units. Modules can be configured for different pack sizes, which is useful for vehicle platforms that share battery technology across multiple models.
The appropriate architecture depends on battery voltage, cell count, packaging constraints, reliability requirements, serviceability, and cost. Regardless of the chosen structure, the design should maintain clear responsibility for measurement, estimation, thermal control, balancing, and safety decisions.
Testing and Validating Thermal Optimization
A thermal-optimization strategy must be validated under realistic and adverse operating conditions. Simulation can help engineers evaluate control algorithms before deployment, while hardware-in-the-loop testing can assess the interaction between embedded software and simulated battery or vehicle behavior.
Testing should include scenarios such as rapid charging, high-power acceleration, regenerative braking, cold starts, elevated ambient temperatures, sensor failures, and communication interruptions.
Engineers can evaluate performance using metrics such as maximum cell temperature, temperature variation across the pack, cooling-system energy consumption, SoC estimation error, balancing losses, and response time to fault conditions.
Battery aging should also be considered. Changes in capacity and internal resistance can alter both thermal behavior and estimation accuracy over time.
Safety-related development should follow applicable standards and vehicle requirements. Depending on the application, relevant frameworks may include ISO 26262 for automotive functional safety, ISO/SAE 21434 for automotive cybersecurity, and applicable battery safety requirements such as UN 38.3 for transport testing. Compliance must be assessed against the specific product, jurisdiction, and intended use.
Future Trends in Microcontroller-Based EV Battery Management
Future BMS architectures are likely to combine more accurate sensing, improved battery models, predictive thermal management, and stronger diagnostic capabilities.
More capable microcontrollers can support sophisticated estimation and control algorithms while maintaining real-time performance. At the same time, dedicated battery-monitoring devices and distributed processing can reduce the computational burden on a central controller.
Digital twins and data-driven models may help predict temperature distribution, battery aging, and maintenance requirements. These methods can improve operational decisions when validated against reliable measurements and representative battery data.
Another emerging direction is tighter integration between battery management, charging infrastructure, and vehicle energy management. By coordinating charging schedules, power limits, and thermal conditions, these systems can improve energy utilization without compromising safety.
Nevertheless, more advanced algorithms do not automatically produce better results. Their benefits depend on sensor accuracy, model quality, validation, fault tolerance, and the ability to execute reliably on the selected hardware.
Final Words
Microcontroller-based battery management system architectures play a central role in improving electric vehicle battery performance, safety, and thermal efficiency. By combining reliable sensor interfaces, accurate SoC estimation, coordinated thermal regulation, and intelligent cell-balancing algorithms, engineers can develop systems that respond effectively to changing battery conditions.
Successful thermal optimization requires more than an advanced control algorithm. It depends on the integration of hardware, embedded software, communication interfaces, diagnostic mechanisms, and rigorous testing. As EV battery systems become more sophisticated, carefully designed BMS architectures will remain essential to extending battery life, improving usable energy, and supporting safer electric mobility.